MOZART Project at IEEE RoboSoft 2025
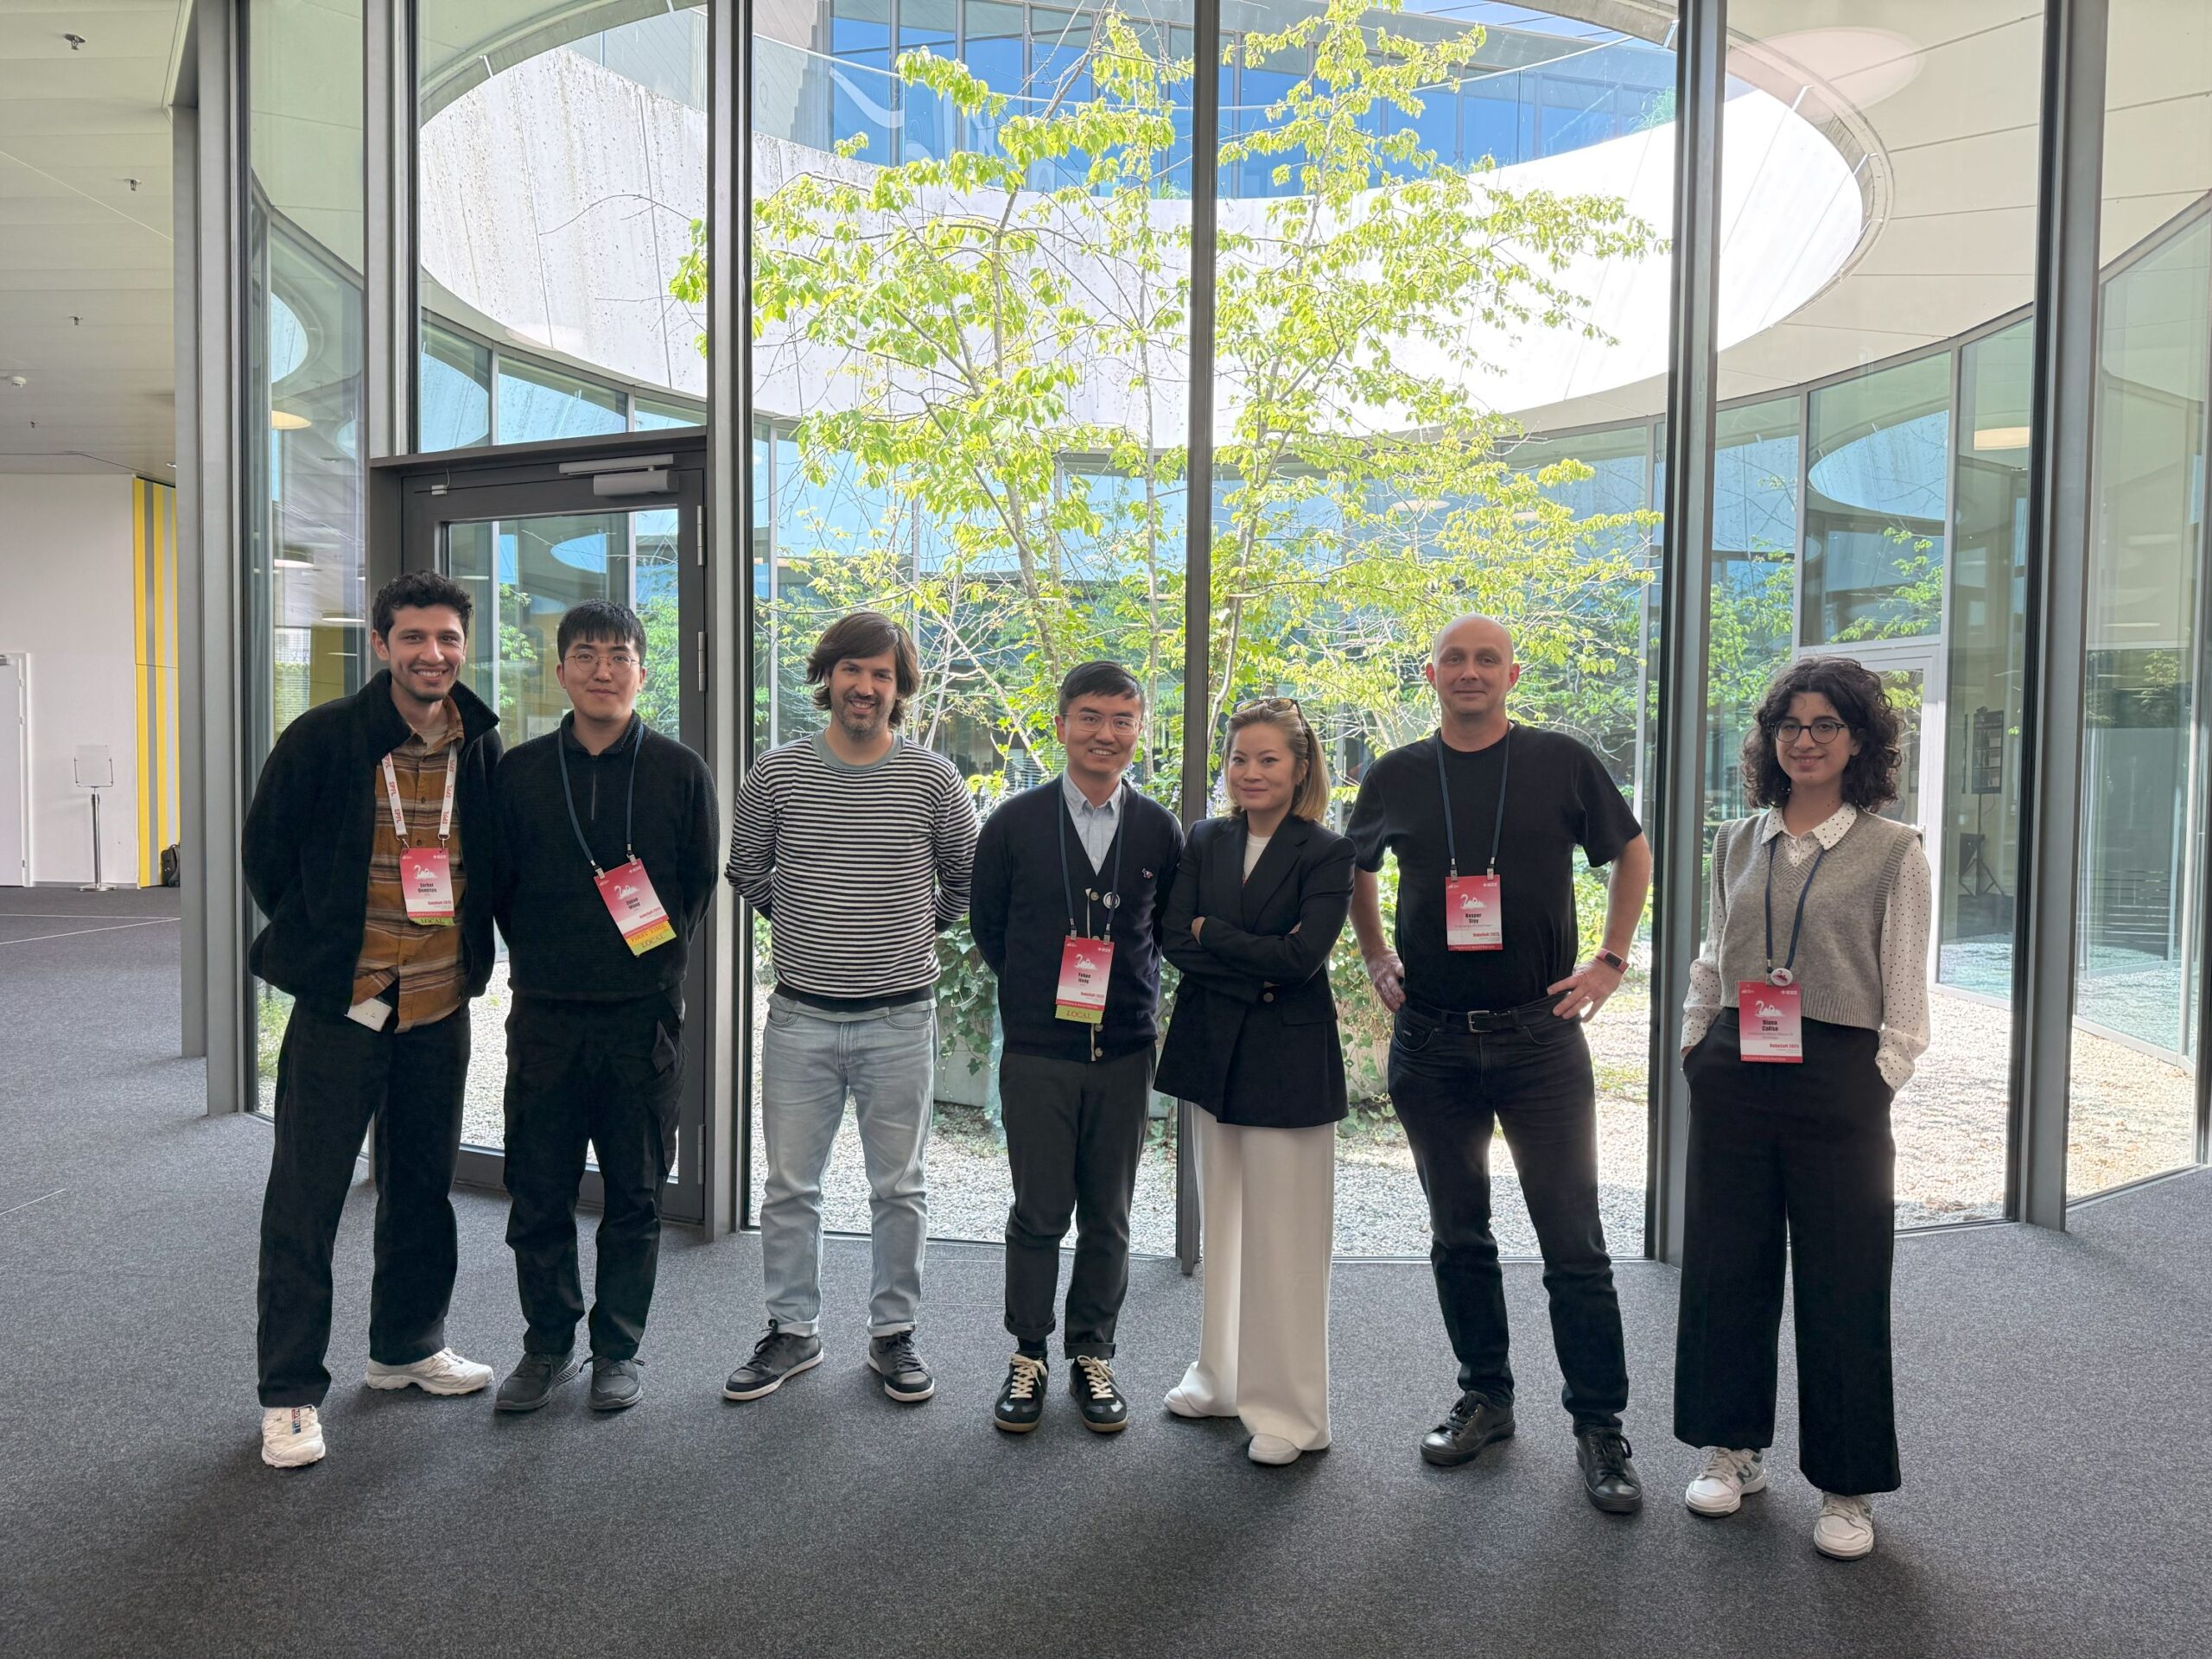
The partners of the MOZART project gathered at IEEE RoboSoft 2025, the 8th IEEE-RAS International Conference on Soft Robotics, held from April 23rd to 26th in Lausanne, Switzerland.
With EPFL among the main organisers of the event, the event embraced the theme “Interdisciplinarity and Widening Horizons,” highlighting collaborative and cross-disciplinary advancements shaping the future of soft robotics.
RoboSoft 2025 brought together leading researchers, industry experts, and students for a dynamic programme that included keynote speeches, forums, demonstrations, lab tours, art exhibitions, and workshops. This environment provided an ideal platform for MOZART partners from EPFL, the IT University of Copenhagen (ITU), and the Istituto Italiano di Tecnologia (IIT) to present the project’s contributions to innovative, interdisciplinary soft robotics research.
Through presentations, discussions, and networking activities, the MOZART team highlighted their progress and the project’s impact on advancing next-generation robotic technologies.
Among the activities, the following poster presentations were featured:
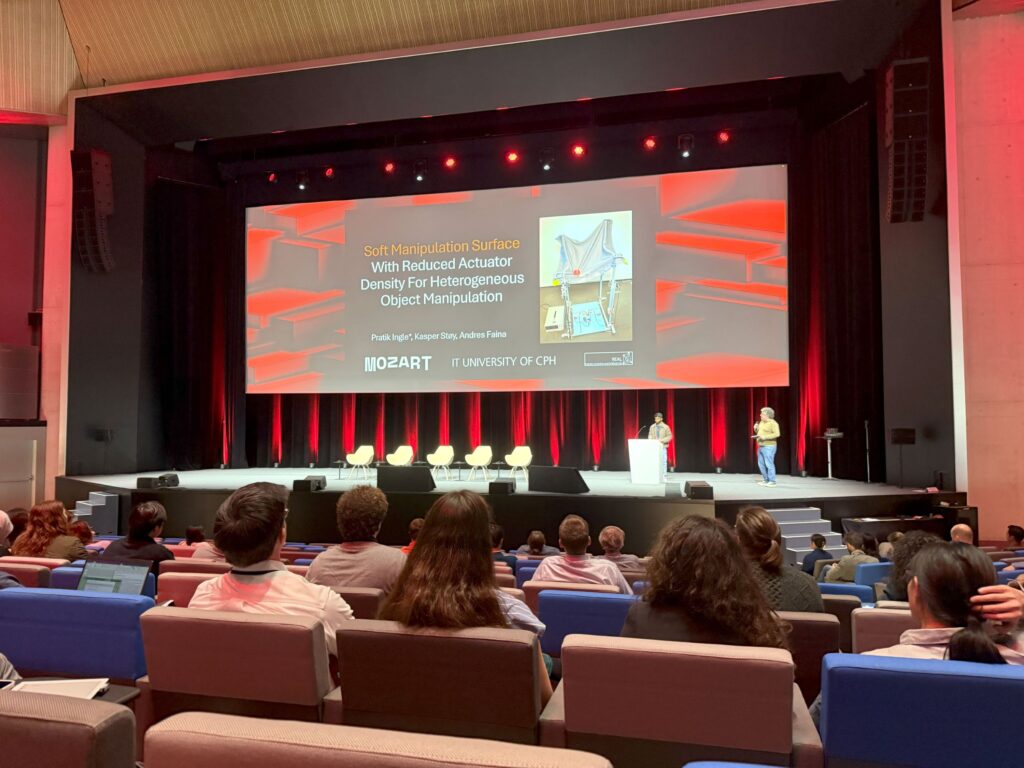
Soft Manipulation Surface with Reduced Actuator Density for Heterogeneous Object Manipulation, by Pratik Ingle, Kasper Støy, and Andres Faiña (IT University of Copenhagen).
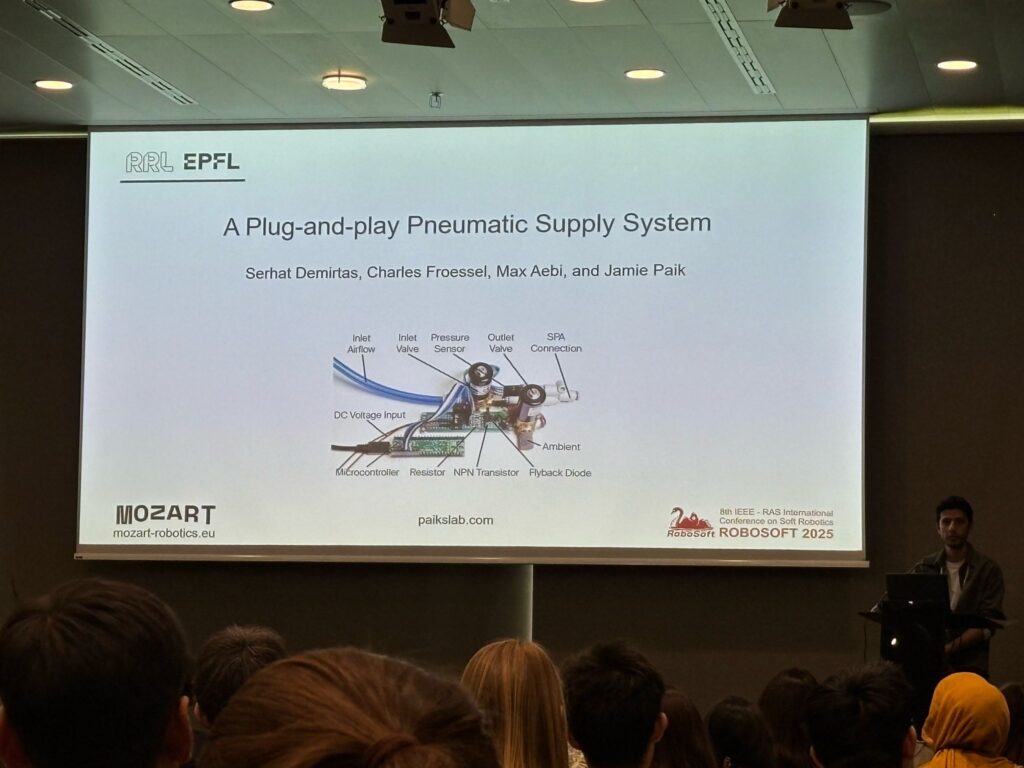
A Plug-and-Play Pneumatic Supply System, by Serhat Demirtaş, Charles Froessel, Max Aebi, and Jamie Paik (Reconfigurable Robotics Lab – EPFL).
CPG-Based Manipulation with Multi-Module Origami Robot Surface, by Yuhao Jiang, Serge El Asmar, Ziqiao Wang, Serhat Demirtaş, and Jamie Paik (Reconfigurable Robotics Lab – EPFL).
The full article is available at this link: CPG-Based Manipulation With Multi-Module Origami Robot Surface | IEEE Journals & Magazine | IEEE Xplore
For more information about RoboSoft 2025, visit robosoft2025.org.